Templates · Robotics
SO-101 style gripper finger
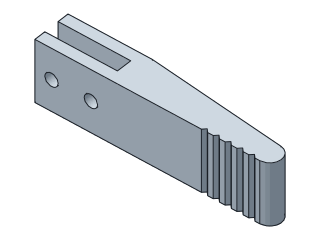
A bolt-on gripper finger in the style of the SO-101 arm: length, opening (slot) width, fingertip thickness and screw hole spacing.
- gripper
- finger
- SO-101
- SO-100
- LeRobot
- robot arm
- 3d printing
- Dwg
- so101-gripper-finger
- Params
- 8
- Units
- mm
Parameters
Open in the editor opens the design with these defaults; change them afterwards in Modify › Parameters, and everything that depends on them follows. Opened from the editor’s template library instead (New ▾ › New from template…), the template asks for its values first and checks them against these ranges and against each other, and Copy link gives an address that opens it with your values.
| Name | What it sets | Default | Range |
|---|---|---|---|
fingerLength | Finger length | 60 mm | 30 to 120 mm, steps of 1 |
openingWidth | Opening (slot) width | 4 mm | 2 to 12 mm, steps of 0.1 |
tipThickness | Fingertip thickness | 6 mm | 3 to 15 mm, steps of 0.5 |
holeSpacing | Mounting hole spacing | 10 mm | 5 to 30 mm, steps of 0.5 |
holeDiameter | Mounting hole diameter | 3.4 mm | 2 to 5.5 mm, steps of 0.1 |
fingerWidth | Finger width | 16 mm | 8 to 30 mm, steps of 0.5 |
wall | Socket wall | 3 mm | 2 to 6 mm, steps of 0.25 |
gripDepth | Grip groove depth | 0.8 mm | 0.3 to 1.5 mm, steps of 0.1 |
Notes
This is a finger in the style of the SO-101 / SO-100 gripper, not an official part: its forked socket slides over a jaw as thick as the opening width and is held by two screws through both prongs and the jaw, so you can try longer, thinner or softer fingers without reprinting the gripper. Measure your jaw: set the opening width to its thickness plus 0.2 to 0.3 mm, and the hole spacing to its holes' spacing (M3 by default; drill the jaw if it has none).
Finger length is from the open end of the socket to the tip; the finger tapers from the socket to the fingertip thickness and ends in a full round. Five V grooves cross the gripping face; deepen them for paper and cloth, or print the finger in TPU for a soft grip.
Print it flat on its side (the gripping face vertical), so the grooves and the slot need no support and the layers run along the finger.
License: CC0 1.0: no rights reserved.